Binary, Hexadecimal And Bit Masks
What You Will Learn
Section titled “What You Will Learn”Read an eight-bit register, convert between binary and hexadecimal, and construct a mask that changes one bit. You need basic C expressions and the Uno pin naming from Blink. No extra hardware is needed for the paper exercises.
One Byte, Eight Decisions
Section titled “One Byte, Eight Decisions”A byte holds eight bits. From bit 7 down to bit 0 their weights are 128, 64, 32, 16,
8, 4, 2 and 1. The pattern 0010 0101 therefore represents 32 + 4 + 1 = 37.
Grouping bits into nibbles makes hexadecimal convenient: 0010 is 2 and 0101
is 5, so the same value is 0x25. A hex digit represents four bits, not four bytes.
| Bit | 7 | 6 | 5 | 4 | 3 | 2 | 1 | 0 |
|---|---|---|---|---|---|---|---|---|
Value in 0x25 |
0 | 0 | 1 | 0 | 0 | 1 | 0 | 1 |
| Weight | 128 | 64 | 32 | 16 | 8 | 4 | 2 | 1 |
In a register, the same byte may represent eight independent controls rather than
the number 37. For DDRB, a one selects output direction for that port bit. The
datasheet defines the meaning; C does not know whether a byte is a count or control.
Set, Clear, Test and Toggle
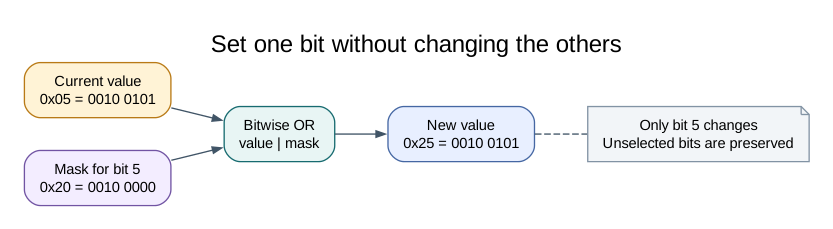
Section titled “Set, Clear, Test and Toggle”PB5 needs the mask 0x20: only bit 5 is one. _BV(PB5) is the AVR header’s spelling
for that mask. The complete, documented program is
01-blink-register/main.c.
Purpose for an ordinary byte value |
Expression | Other bits |
|---|---|---|
| Set bit 5 | `value = (uint8_t)(value | 0x20U);` |
| Clear bit 5 | value = (uint8_t)(value & (uint8_t)~0x20U); |
Preserved |
| Test bit 5 | (value & 0x20U) != 0U |
No write |
| Toggle bit 5 | value = (uint8_t)(value ^ 0x20U); |
Preserved |
For example, 0x05 | 0x20 produces 0x25. Clearing bit 2 then produces 0x21.
The cast narrows the complemented mask deliberately; see
integer promotions for why the intermediate expression is wider.
Logical && and || combine truth values. Bitwise & and | combine individual
bits. Substituting one family for the other changes the calculation.
Registers Have Special Behavior
Section titled “Registers Have Special Behavior”The table applies to ordinary byte storage. Some registers clear flags when a one is written. Others, such as PINB, toggle an output latch on a write of one. A read-modify-write can accidentally acknowledge or toggle every bit that was read as one. Read the register’s access rules before borrowing a familiar expression.
Blink uses PINB = _BV(PINB5); to toggle only PB5. It does not use PINB |= mask.
For DDRB and PORTB, read-modify-write is useful, but shared updates from an ISR and
foreground code still need an ownership or atomicity rule.
Build and Observe
Section titled “Build and Observe”Build 01-blink-register with the commands in Blink. Its source
connects the mask calculation to the onboard LED without an external circuit.
Predict the mask before viewing the code. A mask of 0x10 selects PB4/D12, so it
will not control LED L even though the program compiles.
Exercises with Answers
Section titled “Exercises with Answers”- Convert
1010 0011to hex and decimal. Answer:0xA3, 128 + 32 + 2 + 1 = 163. - Start at
0x81, set bits 2 and 3, then clear bit 7. Answer: OR with0x0Cgives0x8D; AND with0x7Fgives0x0D. - Why not assign
DDRB = 0x20in a shared module? Answer: it also sets every other Port B direction to input, potentially breaking another peripheral.
References and Evidence
Section titled “References and Evidence”For current device details, use the Microchip ATmega328P documentation. Check the document listed for your exact device and package; board-level pin labels and circuitry are covered by the Uno R3 pinout.
Code Walkthrough
Section titled “Code Walkthrough”Example code on GitHub:
Register-level Blink
Section titled “Register-level Blink”The example’s main() configures its peripherals, runs the algorithm and reports or displays the result. These source operations are listed in execution order:
PORTB &= (uint8_t)~_BV(PORTB5);- Sets or clears the Port B output latch. When the pin is an output, this determines its output level; on an input, it controls the pull-up.DDRB |= _BV(DDB5);- Sets the Port B direction bits; a set bit selects output mode.for (;;)- Repeats the foreground task indefinitely; each pass checks inputs, advances the calculation or services the peripheral shown below.PINB = _BV(PINB5);- Writing a one to a PINB bit toggles that pin’s PORTB output latch on the ATmega328P._delay_ms(500);- Waits for the stated interval; the foreground does no other work during this blocking delay.
Algorithm: Pin direction and output latch are separate hardware state. Expected behaviour: L toggles every 500 ms HAL source files in this repository: ATmega328P HAL on GitHub
HAL Software Self-Test
Section titled “HAL Software Self-Test”The example’s main() configures its peripherals, runs the algorithm and reports or displays the result. These source operations are listed in execution order:
avr_debounce_t button;- Use the linked public header for this function’s parameters, register ownership, blocking behavior and status values.uint8_t result = 0U;- Clears the state/counter after its threshold is reached so the next interval starts from zero.(void)avr_uart_init(9600UL);- Configures USART0 for asynchronous 8N1. It chooses a baud divisor and normal/double-speed mode, programs UBRR0/UCSR0A/UCSR0C, then enables receive and transmit in UCSR0B.CHECK(avr_gpio_mode(20U, AVR_GPIO_OUTPUT) == AVR_ERROR_ARGUMENT);- Maps the Uno header pin to its AVR port, sets its DDR direction bit and prepares the PORT latch for the requested initial level or pull-up.CHECK(avr_gpio_read(13U, NULL) == AVR_ERROR_ARGUMENT);- Reads the electrical level through PINx without changing direction or the output latch.CHECK(avr_timer_ctc(AVR_TIMER0, 32U, 100U) == AVR_ERROR_ARGUMENT);- Configures 0 in CTC mode with prescaler 32 and OCRnA TOP 100; event rate is 16 MHz / (32 x (100 + 1)) = 4950.5 Hz. The HAL disables this timer’s interrupt sources and leaves flag polling to the caller.CHECK(avr_timer_ctc(AVR_TIMER0, 64U, 256U) == AVR_ERROR_ARGUMENT);- Configures 0 in CTC mode with prescaler 64 and OCRnA TOP 256; event rate is 16 MHz / (64 x (256 + 1)) = 972.763 Hz. The HAL disables this timer’s interrupt sources and leaves flag polling to the caller.CHECK(avr_timer_ctc(AVR_TIMER2, 128U, 124U) == AVR_OK);- Configures 2 in CTC mode with prescaler 128 and OCRnA TOP 124; event rate is 16 MHz / (128 x (124 + 1)) = 1000 Hz. The HAL disables this timer’s interrupt sources and leaves flag polling to the caller.CHECK((TCCR2B & 7U) == 5U);- Selects Timer2 clock/prescaler and remaining waveform bits. Timer2 has distinct prescaler encodings.CHECK(avr_timer1_pwm(8U, 40000U, 3000U) == AVR_OK);- Configures Timer1 mode 14 with prescaler 8; ICR1 becomes 39999, giving a 20 ms frame, and OCR1A starts at 3000 ticks (1500 us high).CHECK(ICR1 == 39999U && OCR1A == 3000U);- Timer1 input-capture register and, in the selected PWM mode, the TOP value. Timer1 Compare A; it sets the match point or PWM pulse width.CHECK(avr_adc_millivolts(512U, 5000U) == 2500U);- Callsavr_adc_millivolts(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(avr_adc_read(6U, NULL, 0U) == AVR_ERROR_ARGUMENT);- Callsavr_adc_read(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(avr_eeprom_read(1024U, &result, 0UL) == AVR_ERROR_ARGUMENT);- Callsavr_eeprom_read(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(avr_twi_transfer(0U, NULL, 0U, NULL, 0U, 0UL) == AVR_ERROR_ARGUMENT);- Callsavr_twi_transfer(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(avr_elapsed(5UL, UINT32_MAX - 4UL, 10UL));- Callsavr_elapsed(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(!avr_elapsed(5UL, UINT32_MAX - 4UL, 11UL));- Callsavr_elapsed(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.avr_debounce_init(&button, true, UINT32_MAX - 10UL);- Callsavr_debounce_init(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(!avr_debounce_update(&button, false, UINT32_MAX - 9UL, 20U));- Callsavr_debounce_update(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(!avr_debounce_update(&button, false, 9UL, 20U));- Callsavr_debounce_update(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(avr_debounce_update(&button, false, 10UL, 20U));- Accepts a changed input only after it remains stable for the requested interval, then reports that accepted change once.CHECK(!avr_debounce_update(&button, false, 11UL, 20U));- Accepts a changed input only after it remains stable for the requested interval, then reports that accepted change once.(void)avr_uart_write((const uint8_t *)"PASS\n", 5U, AVR_POLL_BUDGET);- Sends the specified bytes through USART0; a timeout can occur after a prefix has already been sent.for (;;)- Repeats the foreground task indefinitely; each pass checks inputs, advances the calculation or services the peripheral shown below.
Algorithm: A bounded self-test checks software contracts and links a second source file so header-owned definitions are detected. Expected behaviour: The fixture prints PASS after argument, timer-range, debounce and independent-translation-unit checks; otherwise it prints FAIL and stops HAL source files in this repository: ATmega328P HAL on GitHub