Integer Widths And Promotions
The Target Matters
Section titled “The Target Matters”For the course AVR compiler configuration, char is one byte, int is 16 bits
and long is 32 bits. A desktop compiler often uses a 32-bit int. A calculation
that appears correct in a PC test can overflow on the Uno before assignment to a
larger destination. Use uint8_t, uint16_t and uint32_t for known-width data;
still reason about the types of intermediate expressions.
The objective is to explain conversions, choose a sufficiently wide intermediate, and identify when wraparound is deliberate. You need bit masks and basic C arithmetic. This is a paper/source-inspection lesson; no circuit is needed.
Widen Before Multiplying
Section titled “Widen Before Multiplying”A ten-bit ADC sample can reach 1023. With a 5000 mV reference, the intermediate
1023 * 5000 is 5,115,000, far beyond 16-bit signed or unsigned range.
Assigning that already-overflowed result to a uint32_t does not repair it.
The HAL’s conversion first widens the sample and multiplies using a 32-bit value. Read adc.c and its contract. The scale uses 1024 ADC bins; half a bin is added before integer division to round to the nearest millivolt. With sample 512 and 5000 mV reference, the calculation yields 2500 mV. For sample 1023 it yields approximately 4995 mV; the largest code does not denote an ideal exact endpoint equal to the reference.
For positive values, integer division discards the fractional remainder. If a
sensor reports 237 tenths of a degree, printing 23 does not mean the measurement
was exactly 23 degrees; retain the remainder to show .7.
Small Operands Are Promoted
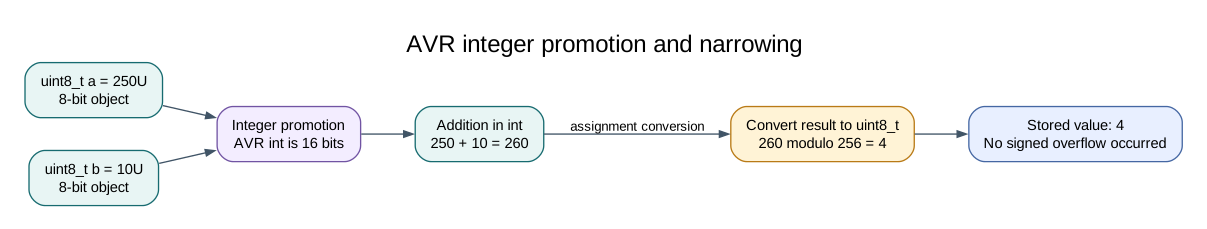
Section titled “Small Operands Are Promoted”Eight-bit operands usually undergo integer promotion before arithmetic. On this
target, every uint8_t value fits in signed int, so a + b for two uint8_t
objects is computed as int. Their maximum sum is 510 and fits. Assigning that sum
back to uint8_t narrows it modulo 256. For example, 250 + 10 becomes 4 after that
conversion. Check the range before narrowing when wrapping is not intended.
Unsigned 16-bit addition wraps modulo 65536. Signed overflow is undefined C behavior; do not use it as a rollover mechanism. Comparisons between signed and unsigned values can also convert a negative value into a large positive value. Validate a signed input before converting it to an unsigned count.
Shifts and Complements
Section titled “Shifts and Complements”The literal 1 has type int. On the AVR, 1 << 15 attempts to produce a value
outside positive signed 16-bit range. Use an unsigned, sufficiently wide operand
and prove the shift count. For a 32-bit mask, UINT32_C(1) << bit requires
bit < 32. No cast after an invalid shift makes the shift valid.
Complementing an eight-bit mask does not necessarily produce an eight-bit result: integer promotions happen first. An explicit narrowing cast can state that only the low eight bits belong in an eight-bit register. A cast documents a justified conversion; it is not a general way to silence warnings.
Exercises with Answers
Section titled “Exercises with Answers”- Can
uint16_t samples[100]fit in 100 bytes? Answer: no, it uses 200 bytes before considering any surrounding object or stack overhead. - A period is 50 ms and a tick is 0.5 us. How many ticks? Answer: 100000, which exceeds a 16-bit timer’s count range. Choose another divider or mode.
- Why widen the ADC sample before multiplication? Answer: the multiply is evaluated using its operands’ types, independently of the destination type.
Verify Your Reasoning
Section titled “Verify Your Reasoning”Build 90-selftest and run the parent npm run test:firmware command. It checks
selected conversion and boundary cases on an AVR instruction model. This is
stronger evidence for target integer behavior than running only a host executable,
but it does not prove all possible inputs correct. -Wconversion is enabled in
both compiler profiles to help expose unintended narrowing.
For current device details, use the Microchip ATmega328P documentation. Check the document listed for your exact device and package; board-level pin labels and circuitry are covered by the Uno R3 pinout.
Code Walkthrough
Section titled “Code Walkthrough”Example code on GitHub:
Measure an analog voltage
Section titled “Measure an analog voltage”The example’s main() configures its peripherals, runs the algorithm and reports or displays the result. These source operations are listed in execution order:
(void)avr_uart_init(9600UL);- Configures USART0 for asynchronous 8N1. It chooses a baud divisor and normal/double-speed mode, programs UBRR0/UCSR0A/UCSR0C, then enables receive and transmit in UCSR0B.(void)avr_adc_init(AVR_ADC_AVCC);- Selects the reference in ADMUX and enables the ADC in ADCSRA with a divide-by-128 prescaler. At 16 MHz, the ADC clock is 125 kHz. The HAL keeps the result right-adjusted, waits for reference settling and leaves ADC interrupts disabled.for (;;)- Repeats the foreground task indefinitely; each pass checks inputs, advances the calculation or services the peripheral shown below.if (avr_adc_read(0U, &sample, AVR_POLL_BUDGET) == AVR_OK)- The body runs only when the conversion succeeds and its code is between 1 and 1022. The HAL selects the channel in ADMUX, disables the digital buffer through DIDR0, discards the first conversion after a channel change, and polls with a finite budget.(void)avr_uart_u16(avr_adc_millivolts(sample, 5000U));- Formats an unsigned integer as decimal digits and sends them on USART0; it does not add a newline. Scales the ADC code with a 32-bit intermediate and the supplied reference voltage. This ideal calculation does not calibrate the reference.(void)avr_uart_put('\n', AVR_POLL_BUDGET);- Waits for the USART transmit buffer within its poll budget, then writes the byte to UDR0._delay_ms(100);- Waits for the stated interval; the foreground does no other work during this blocking delay.
Algorithm: With a nominal 5000 mV reference, one step is 5000/1024=4.8828125 mV. Measure AVCC for accurate scaling; USB supply is not a precision reference. Expected behaviour: Terminal reports approximately 0..4995 mV as the wiper moves HAL source files in this repository: ATmega328P HAL on GitHub
HAL Software Self-Test
Section titled “HAL Software Self-Test”The example’s main() configures its peripherals, runs the algorithm and reports or displays the result. These source operations are listed in execution order:
avr_debounce_t button;- Use the linked public header for this function’s parameters, register ownership, blocking behavior and status values.uint8_t result = 0U;- Clears the state/counter after its threshold is reached so the next interval starts from zero.(void)avr_uart_init(9600UL);- Configures USART0 for asynchronous 8N1. It chooses a baud divisor and normal/double-speed mode, programs UBRR0/UCSR0A/UCSR0C, then enables receive and transmit in UCSR0B.CHECK(avr_gpio_mode(20U, AVR_GPIO_OUTPUT) == AVR_ERROR_ARGUMENT);- Maps the Uno header pin to its AVR port, sets its DDR direction bit and prepares the PORT latch for the requested initial level or pull-up.CHECK(avr_gpio_read(13U, NULL) == AVR_ERROR_ARGUMENT);- Reads the electrical level through PINx without changing direction or the output latch.CHECK(avr_timer_ctc(AVR_TIMER0, 32U, 100U) == AVR_ERROR_ARGUMENT);- Configures 0 in CTC mode with prescaler 32 and OCRnA TOP 100; event rate is 16 MHz / (32 x (100 + 1)) = 4950.5 Hz. The HAL disables this timer’s interrupt sources and leaves flag polling to the caller.CHECK(avr_timer_ctc(AVR_TIMER0, 64U, 256U) == AVR_ERROR_ARGUMENT);- Configures 0 in CTC mode with prescaler 64 and OCRnA TOP 256; event rate is 16 MHz / (64 x (256 + 1)) = 972.763 Hz. The HAL disables this timer’s interrupt sources and leaves flag polling to the caller.CHECK(avr_timer_ctc(AVR_TIMER2, 128U, 124U) == AVR_OK);- Configures 2 in CTC mode with prescaler 128 and OCRnA TOP 124; event rate is 16 MHz / (128 x (124 + 1)) = 1000 Hz. The HAL disables this timer’s interrupt sources and leaves flag polling to the caller.CHECK((TCCR2B & 7U) == 5U);- Selects Timer2 clock/prescaler and remaining waveform bits. Timer2 has distinct prescaler encodings.CHECK(avr_timer1_pwm(8U, 40000U, 3000U) == AVR_OK);- Configures Timer1 mode 14 with prescaler 8; ICR1 becomes 39999, giving a 20 ms frame, and OCR1A starts at 3000 ticks (1500 us high).CHECK(ICR1 == 39999U && OCR1A == 3000U);- Timer1 input-capture register and, in the selected PWM mode, the TOP value. Timer1 Compare A; it sets the match point or PWM pulse width.CHECK(avr_adc_millivolts(512U, 5000U) == 2500U);- Callsavr_adc_millivolts(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(avr_adc_read(6U, NULL, 0U) == AVR_ERROR_ARGUMENT);- Callsavr_adc_read(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(avr_eeprom_read(1024U, &result, 0UL) == AVR_ERROR_ARGUMENT);- Callsavr_eeprom_read(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(avr_twi_transfer(0U, NULL, 0U, NULL, 0U, 0UL) == AVR_ERROR_ARGUMENT);- Callsavr_twi_transfer(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(avr_elapsed(5UL, UINT32_MAX - 4UL, 10UL));- Callsavr_elapsed(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(!avr_elapsed(5UL, UINT32_MAX - 4UL, 11UL));- Callsavr_elapsed(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.avr_debounce_init(&button, true, UINT32_MAX - 10UL);- Callsavr_debounce_init(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(!avr_debounce_update(&button, false, UINT32_MAX - 9UL, 20U));- Callsavr_debounce_update(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(!avr_debounce_update(&button, false, 9UL, 20U));- Callsavr_debounce_update(); its public HAL header defines the arguments, register ownership, blocking behavior and status results.CHECK(avr_debounce_update(&button, false, 10UL, 20U));- Accepts a changed input only after it remains stable for the requested interval, then reports that accepted change once.CHECK(!avr_debounce_update(&button, false, 11UL, 20U));- Accepts a changed input only after it remains stable for the requested interval, then reports that accepted change once.(void)avr_uart_write((const uint8_t *)"PASS\n", 5U, AVR_POLL_BUDGET);- Sends the specified bytes through USART0; a timeout can occur after a prefix has already been sent.for (;;)- Repeats the foreground task indefinitely; each pass checks inputs, advances the calculation or services the peripheral shown below.
Algorithm: A bounded self-test checks software contracts and links a second source file so header-owned definitions are detected. Expected behaviour: The fixture prints PASS after argument, timer-range, debounce and independent-translation-unit checks; otherwise it prints FAIL and stops HAL source files in this repository: ATmega328P HAL on GitHub