Using The SPI HAL
Public Interface
Section titled “Public Interface”The SPI interface is declared in avr_hal/spi.h and implemented in spi.c. avr_spi_init(mode, divider) configures the AVR controller for MSB-first transfers. avr_spi_transfer(transmit, &receive, budget) shifts one byte in and one byte out.
The supported mode values are 0 to 3. Supported clock dividers are 2, 4, 8, 16, 32, 64 and 128. The transfer requires a non-null receive pointer and an initialized controller. It reports explicit statuses for an invalid argument, disabled controller, timeout or write collision.
Pin and Transaction Ownership
Section titled “Pin and Transaction Ownership”The HAL configures D10/SS as an output high, D11/MOSI and D13/SCK as outputs, and D12/MISO as an input. It does not select a peripheral: the application owns each device’s CS signal and must assert and release it around the correct bytes.
Transfers are foreground-only, bounded and nonreentrant. If a timeout occurs, the shift may still be active; deassert CS and reinitialize the peripheral before retrying. Do not call this blocking byte-transfer function from an ISR.
Compare the Consumers
Section titled “Compare the Consumers”The register-level loopback lab shows the peripheral setup and byte sequence. The HAL loopback lab checks whether 0xA5 returns over a jumper wire through the reusable interface. The MAX7219 matrix example uses the same byte interface to send a device-specific register address and value. The HAL knows how to shift a byte; it does not interpret a MAX7219 command.
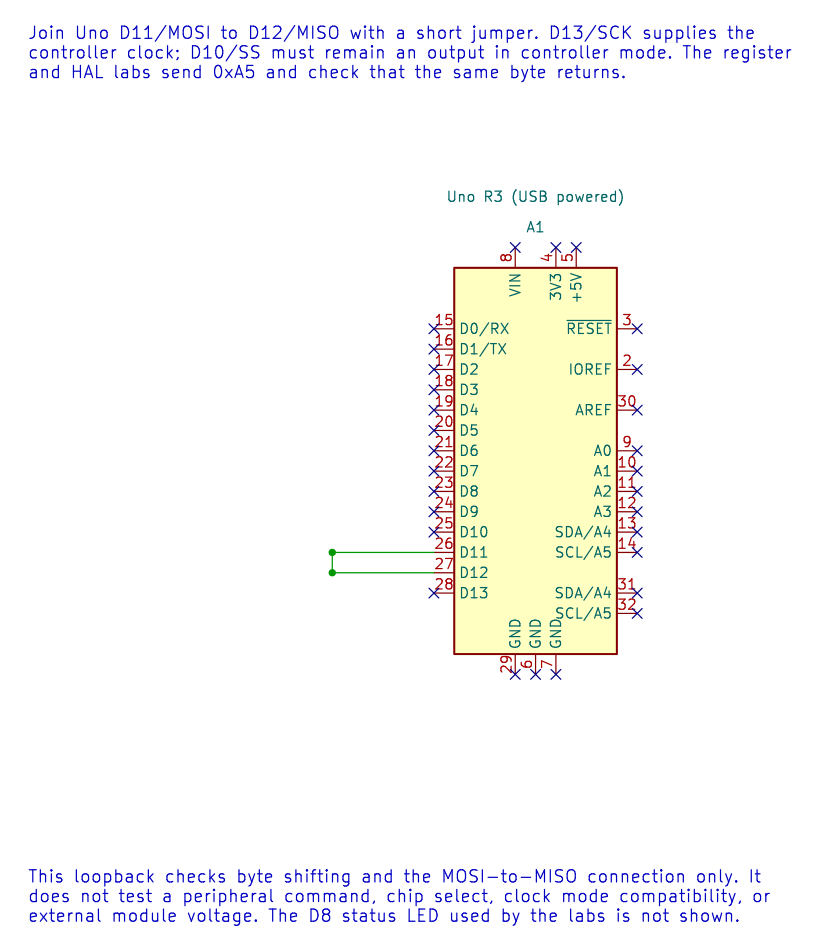
Build 21-spi-loopback or 48-led-matrix-max7219 with the course build script. Inspect the public header for the exact timeout-budget unit and post-error behaviour before writing a new driver.
For example, build both the loopback consumer and MAX7219 consumer with XC8:
python atmega328p-labs/tools/build.py 21-spi-loopback --compiler xc8python atmega328p-labs/tools/build.py 48-led-matrix-max7219 --compiler xc8The loopback return-byte check is suitable for a jumper test. It is not evidence that a MAX7219 module, its supply or its display wiring works.
Exercise with Answer
Section titled “Exercise with Answer”Does avr_spi_transfer() automatically toggle the selected display’s chip-select pin?
Answer: No. The application owns the peripheral CS line. The HAL provides the shared SPI pins and one-byte transfer operation, while the device driver implements the peripheral’s transaction rules.
Code Walkthrough
Section titled “Code Walkthrough”SPI Register-Level Controller Loopback
Section titled “SPI Register-Level Controller Loopback”The example’s main() configures its peripherals, runs the algorithm and reports or displays the result. These source operations are listed in execution order:
uint8_t received = 0U;- Clears the state/counter after its threshold is reached so the next interval starts from zero.for (;;)- Repeats the foreground task indefinitely; each pass checks inputs, advances the calculation or services the peripheral shown below.spi_result_t result = spi_transfer(0xA5U, &received);- Stores this intermediate or output value for the next algorithm step. Check the units and range represented by each operand.bool passed = (result == SPI_RESULT_OK) && (received == 0xA5U);- Stores this intermediate or output value for the next algorithm step. Check the units and range represented by each operand.if (passed)- Tests the stated condition; the following block handles the matching case and the other path is skipped.PORTB |= _BV(PORTB0);- Sets or clears the Port B output latch. When the pin is an output, this determines its output level; on an input, it controls the pull-up.PORTB &= (uint8_t)~_BV(PORTB0);- Sets or clears the Port B output latch. When the pin is an output, this determines its output level; on an input, it controls the pull-up._delay_ms(100);- Waits for the stated interval; the foreground does no other work during this blocking delay.
Algorithm: Directly configures SPCR/SPSR for mode 0 at 16 MHz / 16 = 1 MHz, polls SPIF with a finite iteration budget, reads SPSR before SPDR and checks the returned byte. Expected behaviour: The D8 result LED lights while 0xA5 is received correctly and turns off after a transfer error HAL source files in this repository: ATmega328P HAL on GitHub
SPI controller loopback
Section titled “SPI controller loopback”The example’s main() configures its peripherals, runs the algorithm and reports or displays the result. These source operations are listed in execution order:
(void)avr_spi_init(0U, 16U);- Configures SPI controller mode and clock divider and prepares the Uno SPI pins. Check the call arguments and spi.h for the exact clock setting and pin ownership.(void)avr_gpio_mode(8U, AVR_GPIO_OUTPUT);- Maps the Uno header pin to its AVR port, sets its DDR direction bit and prepares the PORT latch for the requested initial level or pull-up.for (;;)- Repeats the foreground task indefinitely; each pass checks inputs, advances the calculation or services the peripheral shown below.avr_status_t status = avr_spi_transfer(0xA5U, &received, AVR_POLL_BUDGET);- Writes one byte to SPDR, waits within the poll budget for completion and returns the simultaneously received byte.(void)avr_gpio_write(8U, (status == AVR_OK) && (received == 0xA5U));- Changes the pin’s PORT output latch; for an input pin this selects its pull-up state._delay_ms(100);- Waits for the stated interval; the foreground does no other work during this blocking delay.
Algorithm: At divider 16, SCK=1 MHz. Loopback verifies shifting and wiring but does not verify a peripheral command set or chip-select timing. Expected behaviour: D8 LED lights if 0xA5 returns correctly HAL source files in this repository: ATmega328P HAL on GitHub
MAX7219 8x8 LED matrix
Section titled “MAX7219 8x8 LED matrix”The example’s main() configures its peripherals, runs the algorithm and reports or displays the result. These source operations are listed in execution order:
avr_status_t status = matrix_show_a();- Use the linked public header for this function’s parameters, register ownership, blocking behavior and status values.if (status != AVR_OK)- Tests the stated condition; the following block handles the matching case and the other path is skipped.(void)avr_gpio_write(MATRIX_CS_PIN, true);- Changes the pin’s PORT output latch; for an input pin this selects its pull-up state.for (;;)- Repeats the foreground task indefinitely; each pass checks inputs, advances the calculation or services the peripheral shown below.
Algorithm: The MAX7219 scans the matrix internally and accepts addressed register writes over SPI mode 0. Expected behaviour: The matrix displays a capital A; orientation may differ by module HAL source files in this repository: ATmega328P HAL on GitHub
References
Section titled “References”- SPI HAL header and implementation
- SPI programming The current HAL headers and implementation are documented in the HAL Library README and API comments.
- SPI loopback schematic and verified netlist
- Rendered loopback diagram