ATmega328P TWI Registers
Main TWI Registers
Section titled “Main TWI Registers”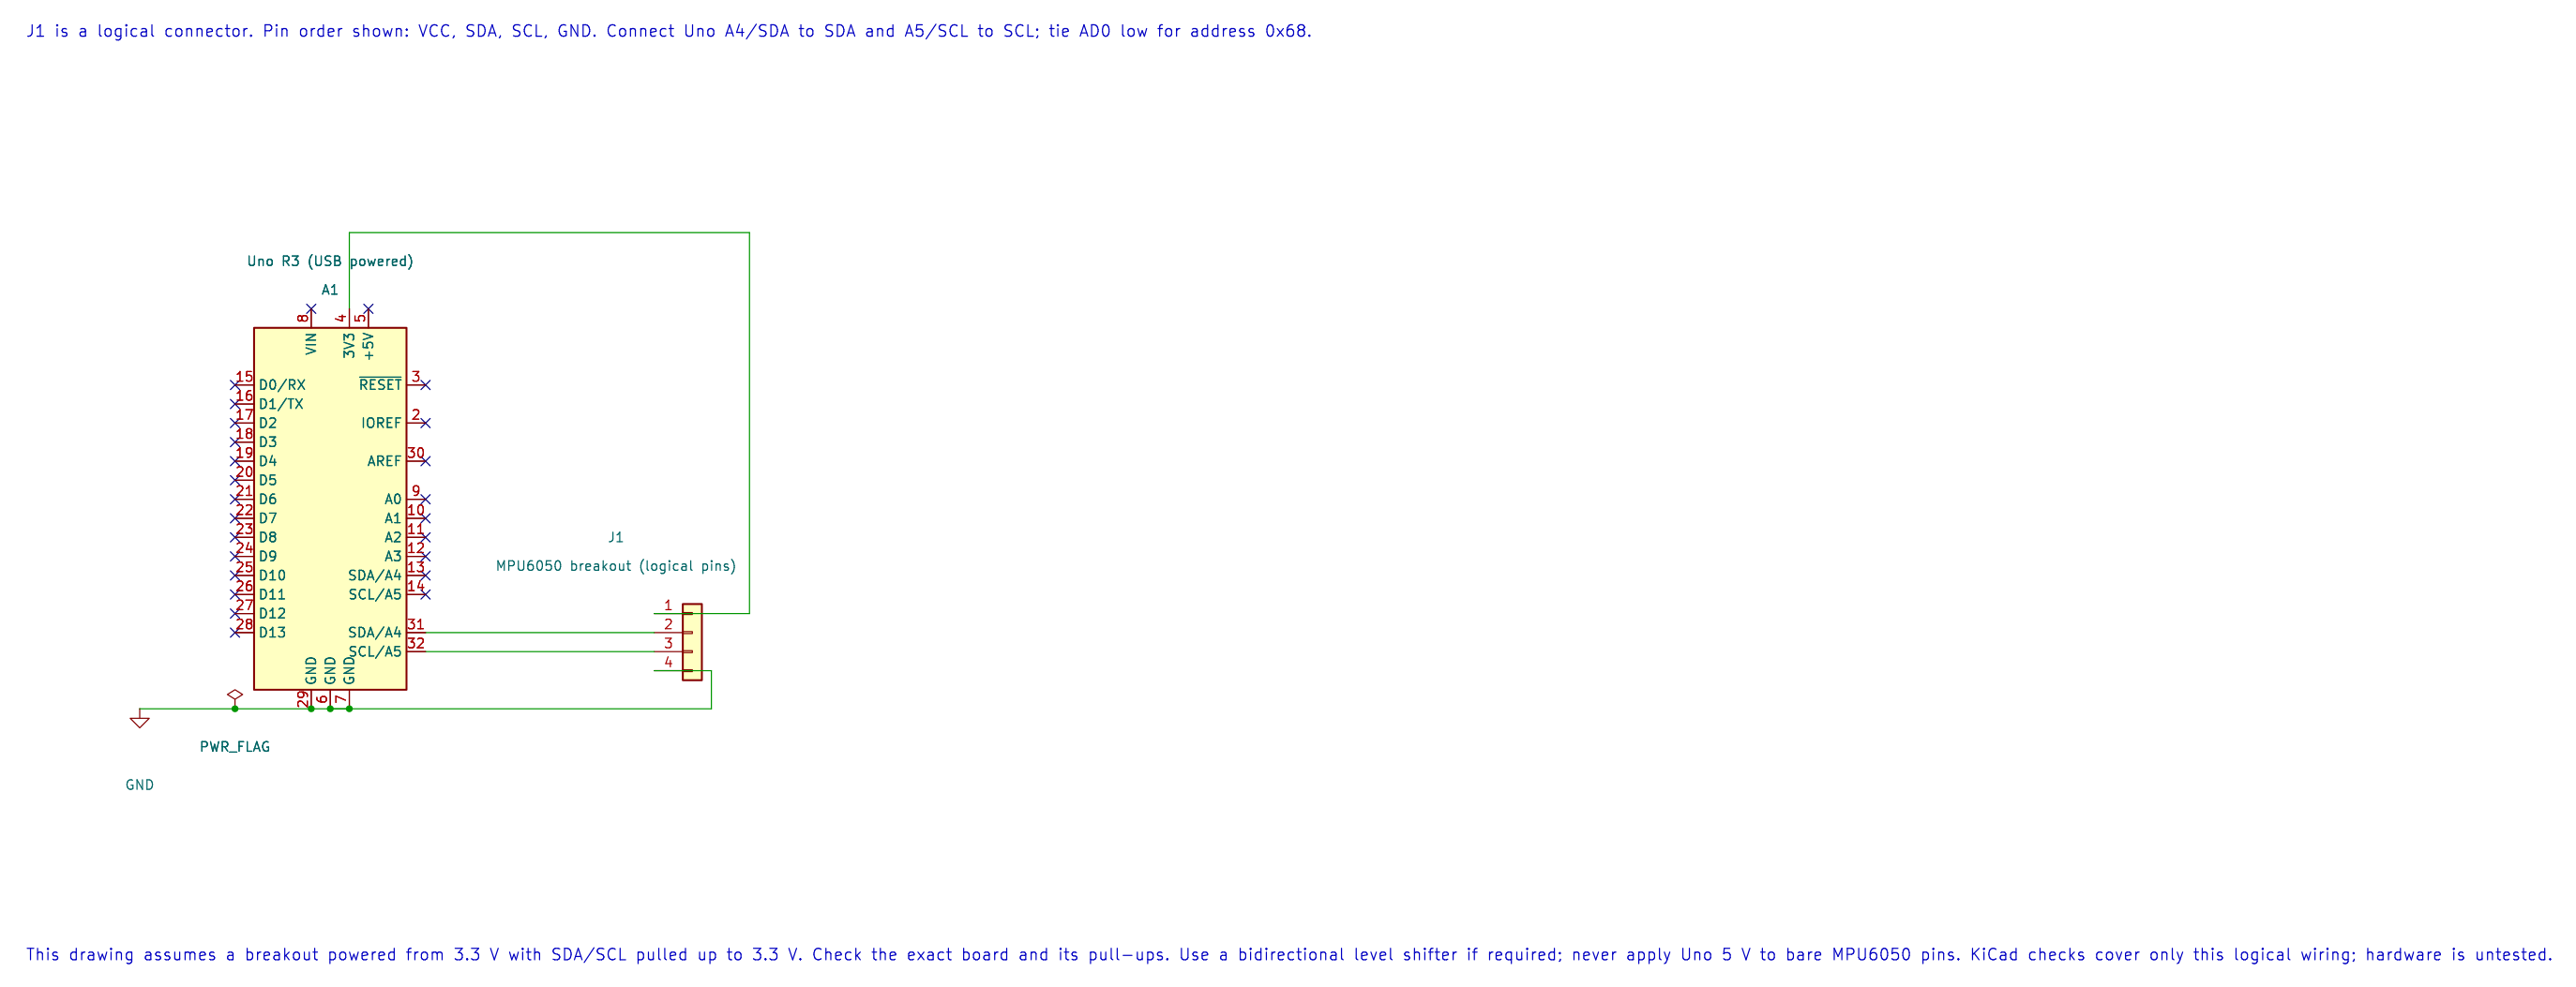
| Register | Role |
|---|---|
TWBR |
Bit-rate divider |
TWSR |
Prescaler selection and protocol status code |
TWCR |
Enable, START, STOP, ACK and interrupt/flag control |
TWDR |
Address or data byte sent/received |
TWAR |
Own address when operating as a peripheral |
TWAMR |
Optional address mask for peripheral mode |
In controller mode, the SCL rate depends on CPU clock, TWBR and the prescaler selected by TWPS1:0 in TWSR:
f_SCL = F_CPU / (16 + 2 × TWBR × prescaler)At the Uno’s 16 MHz clock with prescaler 1, 100 kHz uses TWBR = (16,000,000 / 100,000 - 16) / 2 = 72. For 400 kHz, TWBR = 12. The course HAL supports these two rates at the reference clock. The calculated divider does not replace the electrical checks: use external pull-ups and make sure every module supports the selected bus voltage and speed.
For a 100 kHz controller, the key register setup is:
TWSR = 0U; /* TWPS1:0 = 0: prescaler is 1. */TWBR = 72U;TWCR = _BV(TWEN); /* Enable TWI without enabling its interrupt. */Build the direct-register example under both compilers:
python atmega328p-labs/tools/build.py 74-twi-register-read --compiler gccpython atmega328p-labs/tools/build.py 74-twi-register-read --compiler xc8The setup assumes the TWI bus is idle and the module uses compatible pull-ups. A peripheral driver should not enable global interrupts as a side effect.
Compare the Direct-Register Example
Section titled “Compare the Direct-Register Example”Lab 74 performs the WHO_AM_I read without calling the TWI HAL. It checks the status after every phase: TW_START, TW_MT_SLA_ACK, TW_MT_DATA_ACK, TW_REP_START, TW_MR_SLA_ACK and TW_MR_DATA_NACK. It reads TWDR only after the final status matches. The code also places a finite bound on every TWINT wait and on STOP completion.
If the address is not acknowledged, the status is TW_MT_SLA_NACK or TW_MR_SLA_NACK; the example attempts a bounded STOP and leaves the result LED off. If arbitration is lost, it clears the event and releases TWI without sending STOP. Compare this phase-by-phase code with the HAL in Lab 32, which uses the same underlying transaction through a reusable API.
Status Codes and Twint
Section titled “Status Codes and Twint”The status bits in TWSR report the most recently completed bus step. Common controller-transmit and controller-receive statuses include:
| Status | Meaning |
|---|---|
0x08 / 0x10 |
START / repeated START transmitted |
0x18 / 0x20 |
SLA+W acknowledged / not acknowledged |
0x28 / 0x30 |
Data byte acknowledged / not acknowledged |
0x38 |
Arbitration lost |
0x40 / 0x48 |
SLA+R acknowledged / not acknowledged |
0x50 / 0x58 |
Received byte acknowledged / final byte received with NACK |
TWINT signals that the current bus step has completed. Software writes a one to TWINT while issuing the next control command to clear the flag and continue the state machine. Every wait for TWINT needs a finite timeout so a stuck bus cannot trap the firmware forever.
Do not treat status flags like ordinary RAM. Check the masked status in TWSR before advancing. A NACK is different from a timeout or arbitration loss, and each result needs a different recovery decision. After losing arbitration, release the bus instead of sending STOP as though this controller still owned it.
Start a Controller Transaction
Section titled “Start a Controller Transaction”This register sequence fragment requests START, waits for TWINT, checks for status 0x08, then loads the address byte. The wait function is intentionally omitted here; a real implementation must bound it and check every resulting status before proceeding.
#include <util/twi.h>
TWCR = _BV(TWINT) | _BV(TWSTA) | _BV(TWEN);/* Wait with a finite budget, then require (TWSR & 0xF8U) == TW_START. */TWDR = (uint8_t)((address << 1U) | TW_WRITE);TWCR = _BV(TWINT) | _BV(TWEN);/* Wait with a finite budget, then require the expected address-ACK status. */
TWINT is written as one to continue. In the address byte, TW_WRITE is zero and TW_READ is one; the HAL accepts the unshifted seven-bit address and creates this byte itself. The software fixtures 99 and 100 model a successful identity read and an address NACK; neither is a physical bus test.
Exercise with Answer
Section titled “Exercise with Answer”Why should TWI code report a NACK separately from a timeout?
Answer: A NACK means the bus step completed and the addressed device or byte was not acknowledged. A timeout means the expected state did not complete within the polling budget. The likely causes and recovery actions are different.
Code Walkthrough
Section titled “Code Walkthrough”Example code on GitHub:
Direct-Register TWI Identity Read
Section titled “Direct-Register TWI Identity Read”The example’s main() configures its peripherals, runs the algorithm and reports or displays the result. These source operations are listed in execution order:
uint8_t identity = 0U;- Clears the state/counter after its threshold is reached so the next interval starts from zero.DDRB |= _BV(DDB5);- Sets the Port B direction bits; a set bit selects output mode.PORTB &= (uint8_t)~_BV(PORTB5);- Sets or clears the Port B output latch. When the pin is an output, this determines its output level; on an input, it controls the pull-up.twi_result_t result = mpu6050_register_read(MPU6050_WHO_AM_I_REGISTER, &identity);- Stores this intermediate or output value for the next algorithm step. Check the units and range represented by each operand.if ((result == TWI_RESULT_OK) && (identity == MPU6050_WHO_AM_I_VALUE))- Tests the stated condition; the following block handles the matching case and the other path is skipped.PORTB |= _BV(PORTB5);- Sets or clears the Port B output latch. When the pin is an output, this determines its output level; on an input, it controls the pull-up.for (;;)- Repeats the foreground task indefinitely; each pass checks inputs, advances the calculation or services the peripheral shown below.
Algorithm: Directly controls TWBR/TWSR/TWCR/TWDR, checks each TWI status, uses repeated START, NACKs the final byte and bounds waits. Expected behaviour: D13 turns on when WHO_AM_I register 0x75 returns 0x68 HAL source files in this repository: ATmega328P HAL on GitHub
TWI address probe
Section titled “TWI address probe”The example’s main() configures its peripherals, runs the algorithm and reports or displays the result. These source operations are listed in execution order:
(void)avr_twi_init(100000UL);- Configures TWI for the requested bus rate and enables the peripheral. The bus still requires suitable external pull-ups and compatible signal voltage.(void)avr_uart_init(9600UL);- Configures USART0 for asynchronous 8N1. It chooses a baud divisor and normal/double-speed mode, programs UBRR0/UCSR0A/UCSR0C, then enables receive and transmit in UCSR0B.for (;;)- Repeats the foreground task indefinitely; each pass checks inputs, advances the calculation or services the peripheral shown below.for (uint8_t address = 8U; address < 0x78U; ++address)- Repeats whileaddress < 0x78Uis true;uint8_t address = 8Usets the starting state and++addressadvances it each pass.if (avr_twi_transfer(address, NULL, 0U, NULL, 0U, AVR_POLL_BUDGET) == AVR_OK)- The operation runs only after this API reports AVR_OK. Performs a bounded TWI transaction at the requested 7-bit address; the result reports address/data phase errors.(void)avr_uart_u16(address);- Formats an unsigned integer as decimal digits and sends them on USART0; it does not add a newline.(void)avr_uart_put('\n', AVR_POLL_BUDGET);- Waits for the USART transmit buffer within its poll budget, then writes the byte to UDR0._delay_ms(1000);- Waits for the stated interval; the foreground does no other work during this blocking delay.
Algorithm: Address 0x68 is printed as decimal 104. Do not shift an address before passing it to this HAL. Probe only devices whose datasheets allow an empty write transaction. Expected behaviour: Responding 7-bit addresses print in decimal; an empty bus prints none HAL source files in this repository: ATmega328P HAL on GitHub
Register-Level TWI Scripted Device Fixture
Section titled “Register-Level TWI Scripted Device Fixture”The example’s main() configures its peripherals, runs the algorithm and reports or displays the result. These source operations are listed in execution order:
Algorithm: Checks the START, address, register, repeated-START, read-NACK and STOP sequence on simulated registers. Expected behaviour: A scripted address ACK and WHO_AM_I byte set the D13 success output HAL source files in this repository: ATmega328P HAL on GitHub
Register-Level TWI Address-NACK Fixture
Section titled “Register-Level TWI Address-NACK Fixture”The example’s main() configures its peripherals, runs the algorithm and reports or displays the result. These source operations are listed in execution order:
Algorithm: Exercises the address-NACK error and bounded STOP cleanup path. Expected behaviour: The simulated sensor does not ACK; the D13 success output remains off and cleanup requests STOP HAL source files in this repository: ATmega328P HAL on GitHub
References
Section titled “References”- Microchip, ATmega328P documentation, TWI register summary and status codes.
- TWI HAL header
- Direct-register TWI identity read, register-read test fixture, address-NACK test fixture and HAL MPU6050 example
- TWI concepts